STEITR
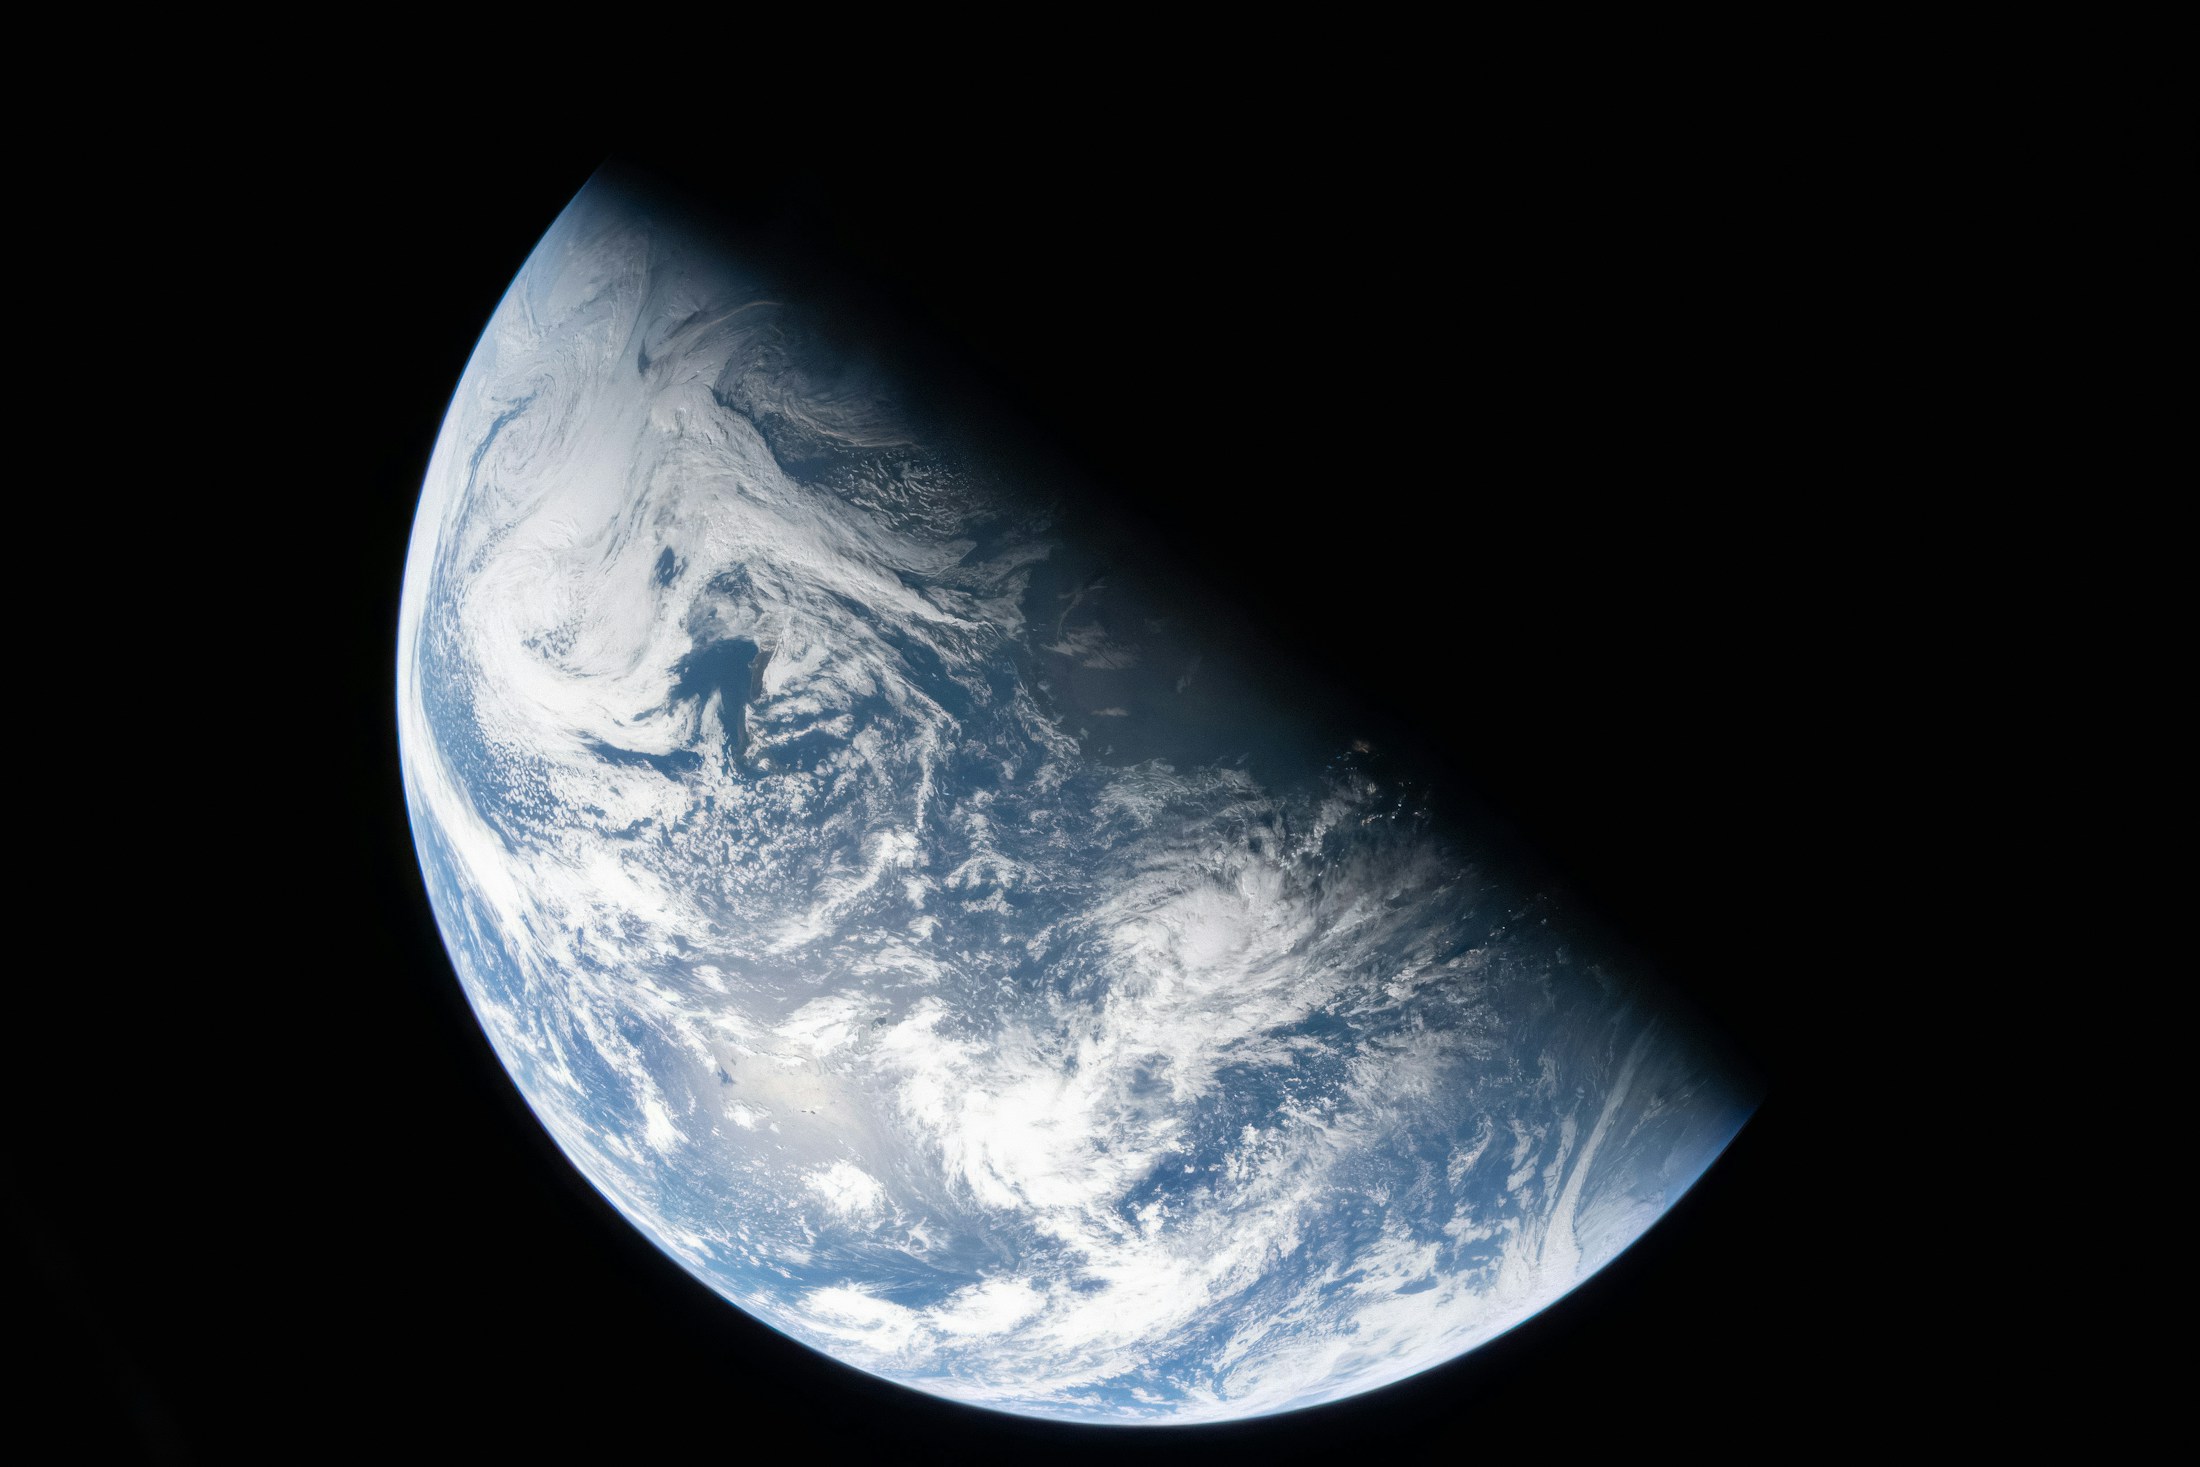
Earth seen from orbit
CONTINUUM ROBOTICSMILAN, ITALY / A WIDER HORIZON

Machines for
the inaccessible.

A different kind of reach.
In orbit. On Earth. Beneath the surface.

Discover our approach
01 / IN ORBIT

Reaching further.
Working beyond Earth.

FUTURE SPACE SERVICING & EXPLORATION
FLEXIBILITY IS A FORM OF STRENGTH.SCROLL TO EXPLORE

The world doesn’t move
in straight lines.
Neither should robots.

Nature reaches, bends and adapts. We bring that way of moving to machines.

STEITR is creating metallic continuum robotic systems that bend along their length to reach around obstacles and navigate complex spaces. We bring structural design and robotic control together to make useful work possible where conventional access reaches its limits.

THE CHALLENGE

Beyond the factory floor.

Conventional jointed arms need room to move. In confined or exposed environments, access becomes harder, while radiation, thermal cycling and pressure create additional demands on joints, seals and electronics. Reaching the asset is only part of the task; the machine must also work reliably around it.

OUR RESPONSE

Protect what drives the motion.

STEITR separates the exposed arm from its actuators and electronics, allowing these sensitive components to be protected outside the arm itself. The metallic continuum body bends along its length to reach around obstacles. This approach brings adaptable access to inspection and intervention, with performance evaluated against each application’s requirements.

WHY IT MATTERS

New work for robotics.

Industrial inspection, underwater infrastructure and satellite servicing all create tasks beyond conventional automation. In space, investment is moving towards extending the life of existing assets: ESA’s €119 million RISE contract with D-Orbit is one concrete example of this direction.

Source: ESA, RISE mission
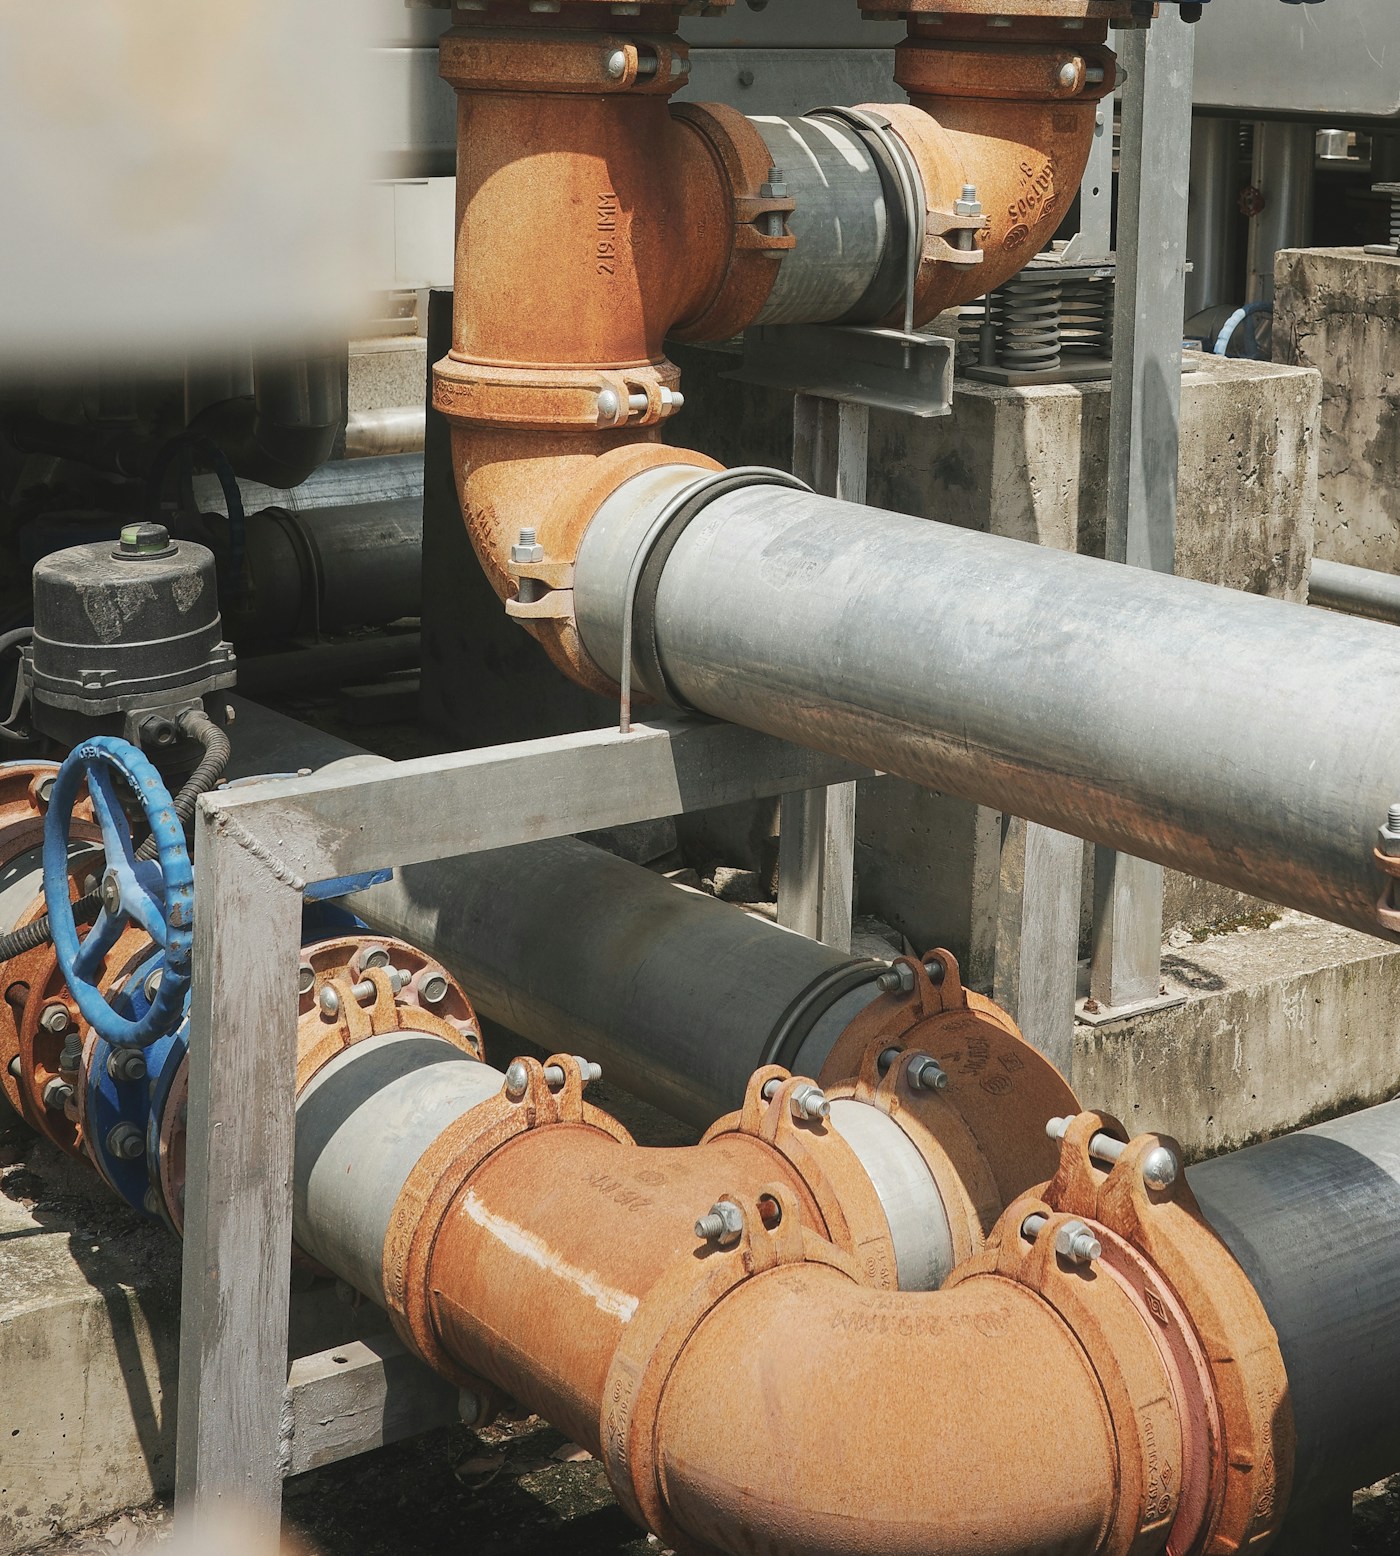
Pipes and equipment inside an industrial facility

Closer to the work.
Further from the risk.

Complex equipment leaves little room for conventional access. We are exploring adaptable robotic systems for inspection and manipulation in constrained industrial environments.

ENERGY / INSPECTION / CONSTRAINED ACCESS

Immediate focus: define useful demonstrations with industrial teams, around a clear task and measurable requirements.

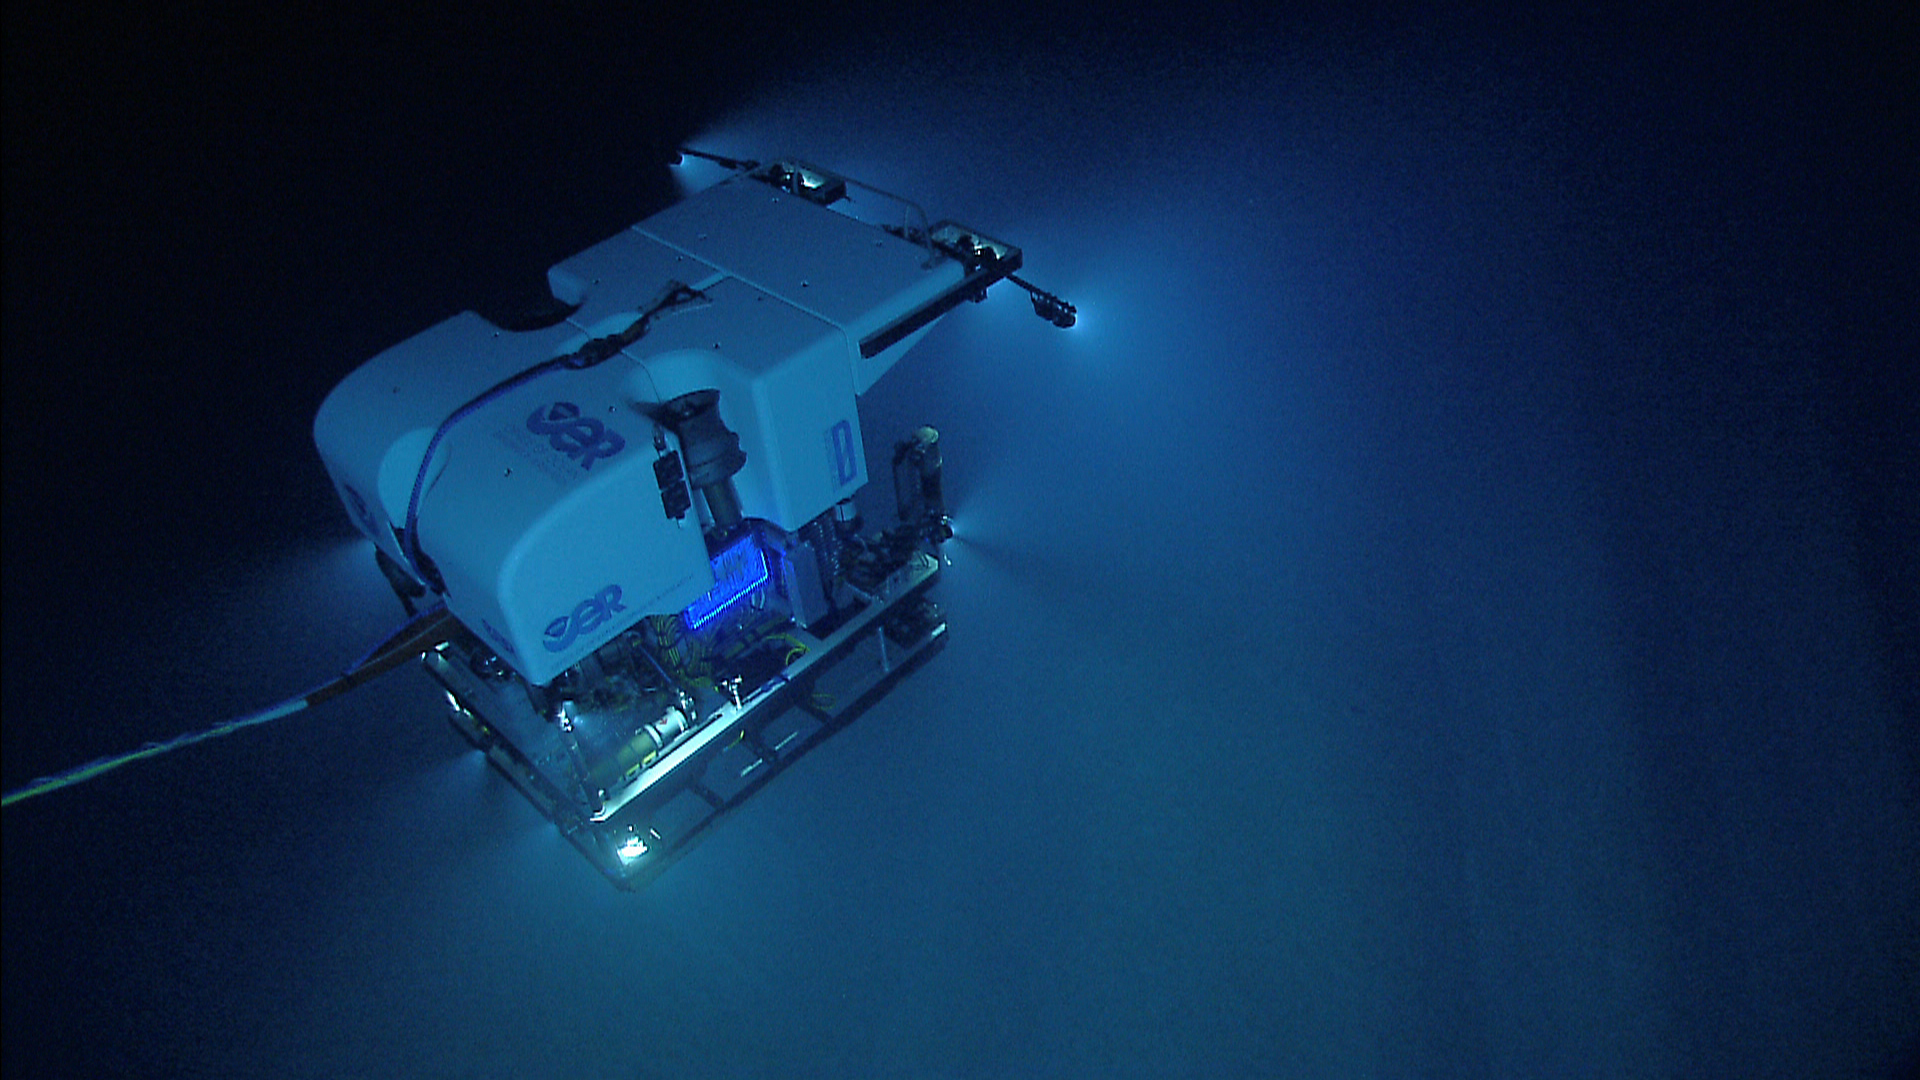
NOAA’s Deep Discoverer ROV submerged in the deep ocean

A new depth
of possibility.

The deep ocean asks more of every machine. Our long-term direction includes dexterous access for inspection and intervention around complex underwater infrastructure.

OCEAN / INFRASTRUCTURE / INTERVENTION

Each environment brings its own engineering and qualification requirements. These application areas describe our direction.

CONTEXTUAL PHOTOGRAPHY: NOAA / DEEP DISCOVERER
01 / NOW

Define the mission

Work with industrial teams to frame difficult access problems and scope useful demonstrations.

02 / NEXT

Prove in the field

Test performance against application requirements and develop systems around customer tasks.

03 / HORIZON

Reach beyond Earth

Pursue the qualification and partnerships needed for future space operations.

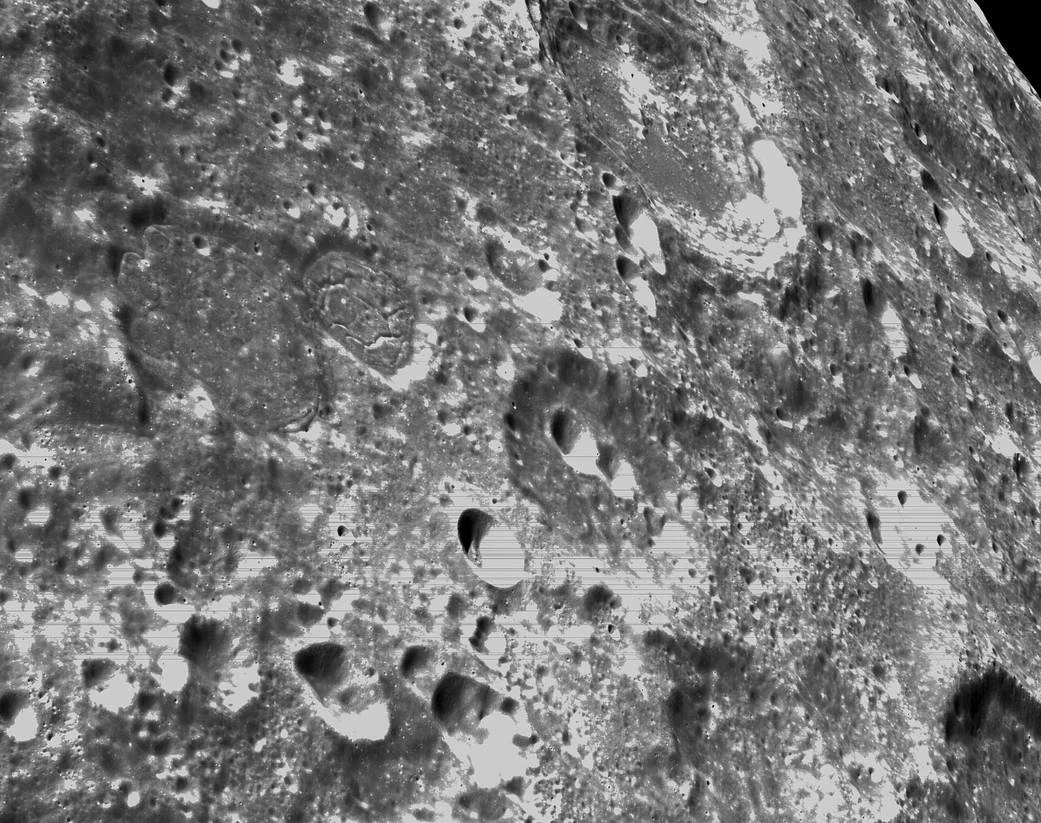
Craters on the lunar surface photographed by Orion

Born in research.
Built for the field.

STEITR grew from research in bio-inspired robotics and advanced structures at Politecnico di Milano.

We bring mechanics, modelling and robotic control together to extend human capability into places that remain difficult to reach. As part of TEF Foundry, we connect technical work with commercial validation.

ROBOTICS & CONTROL

Ali Golozar

Doctoral research in robotics at Politecnico di Milano. Focused on robotic movement, control and the needs of demanding applications.

LinkedIn
STRUCTURES & MANUFACTURING

Giacomo Brambilla

Doctoral research in metamaterials and metastructures at Politecnico di Milano. Connecting structural design with physical behaviour.

LinkedIn
BUSINESS & FINANCE

Tommaso Santolin

MSc from KU Leuven. Experience across start-ups, scale-ups, investment banking and multinational manufacturing, with experience across six countries.

LinkedIn

Institutional marks identify research origins and programme participation. They do not imply endorsement of this website or its claims.

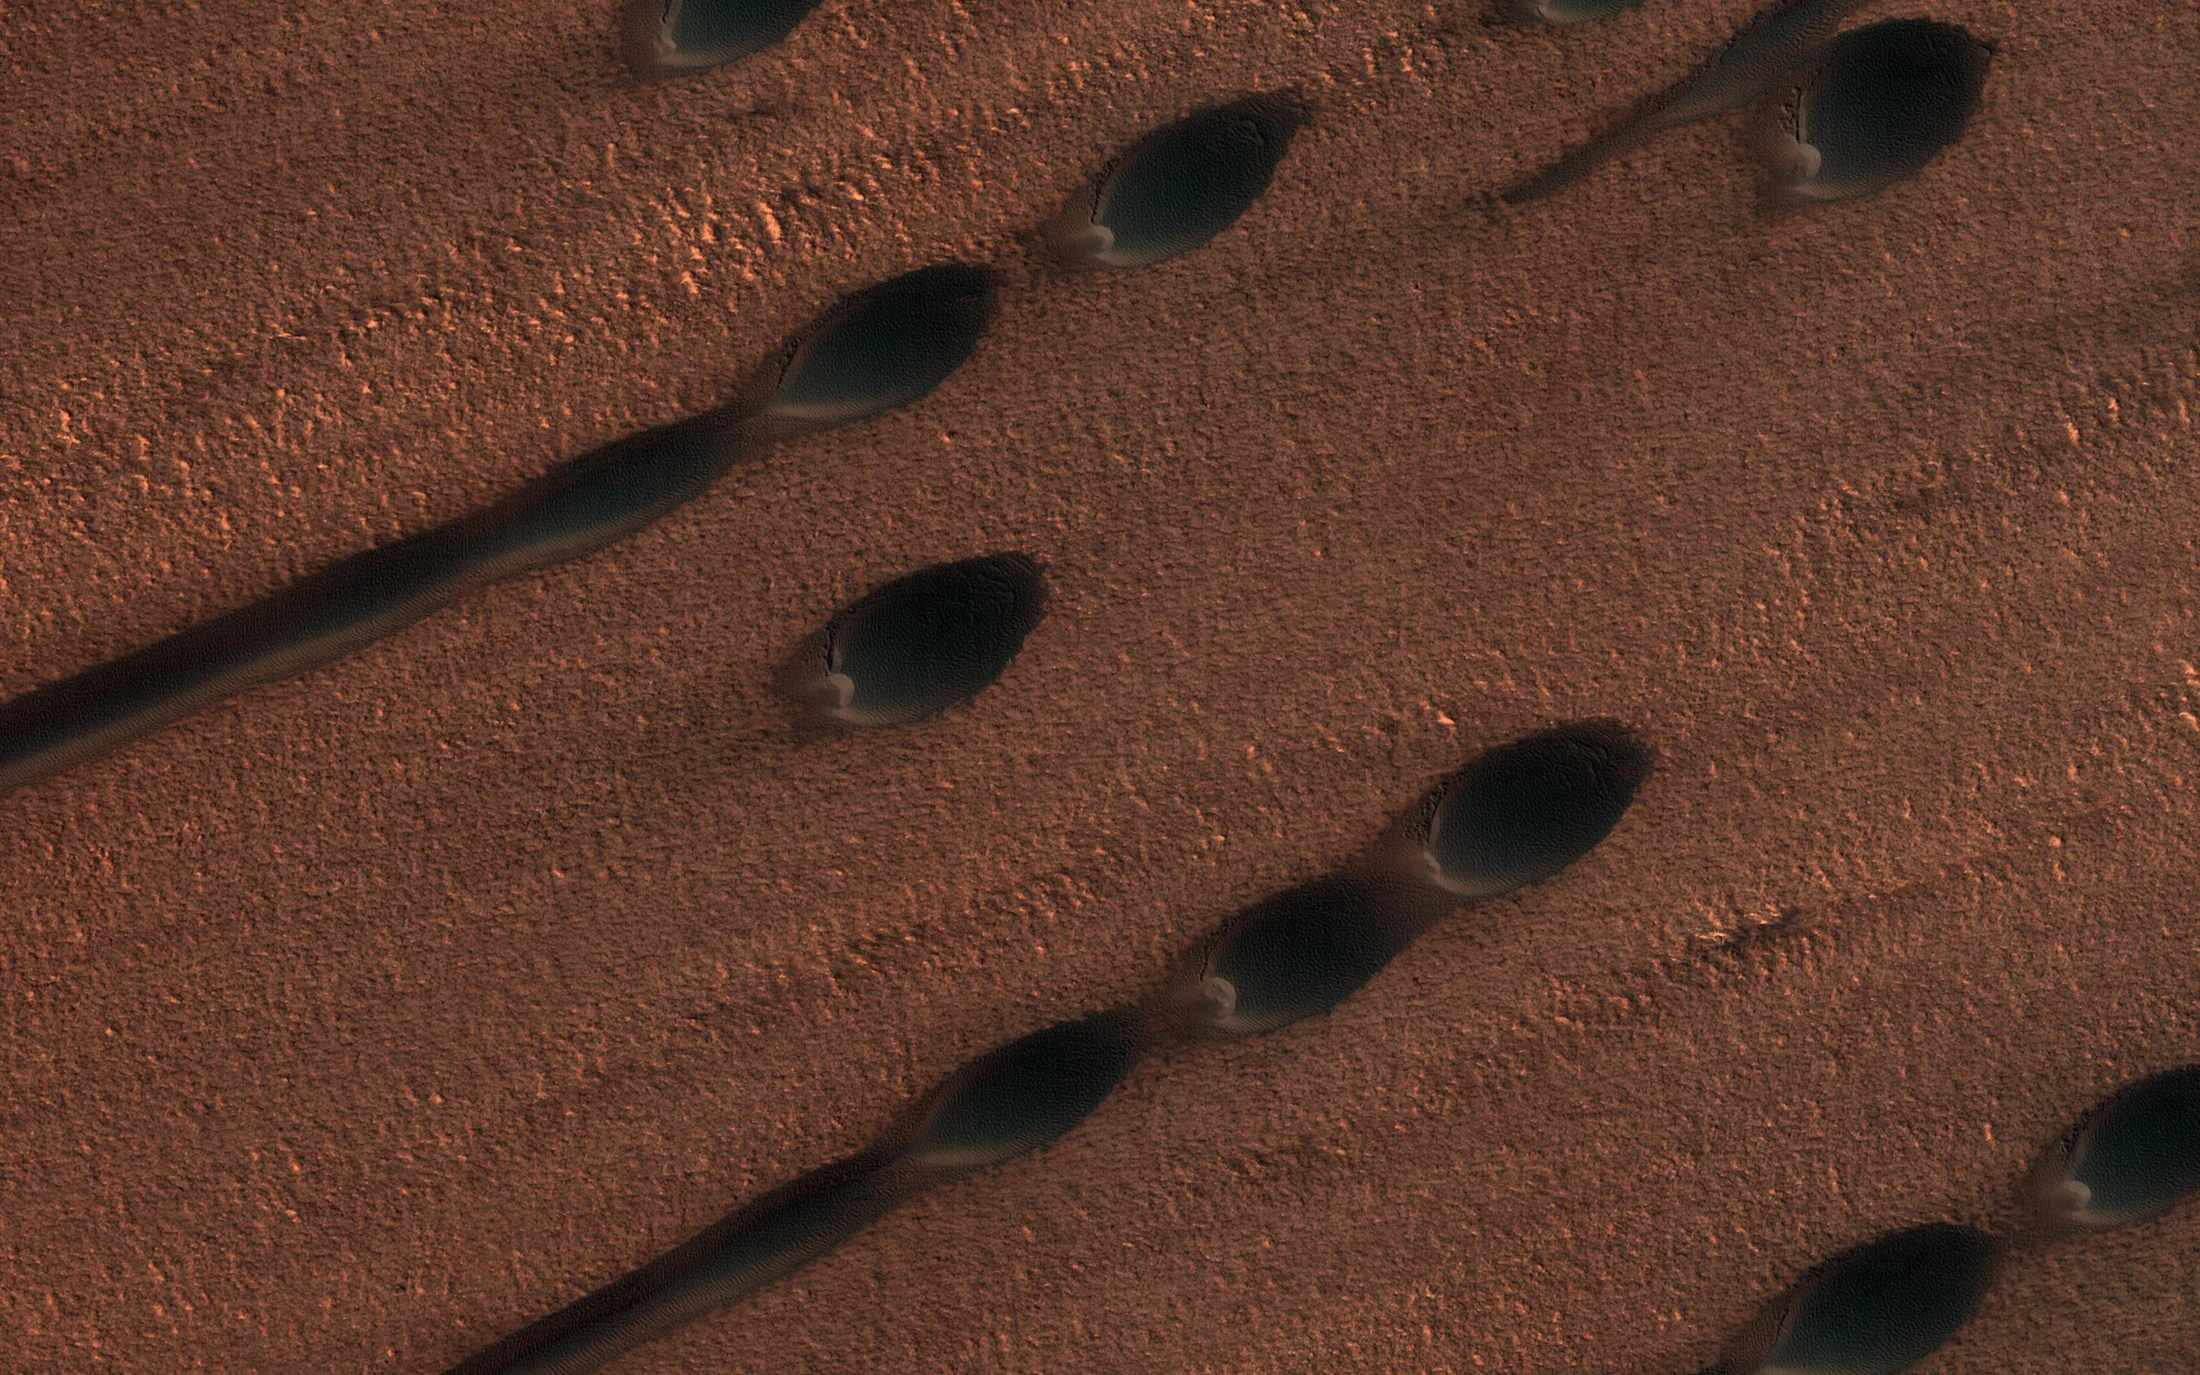
Wind-shaped dunes on the surface of Mars

The next frontier
takes a team.

Drawn to hard physical problems?

We want to meet people working across robotics, structures, materials and control. Tell us what you have built and what you want to tackle next. We welcome thoughtful introductions, even when no specific role is listed.

Introduce yourself
LET’S EXPAND WHAT’S POSSIBLE

What’s just
out of reach?

Bring us a challenging environment.
Let’s explore what robotics could make possible.

Talk to STEITR